The hard part of physical AI? Making it safe.
Driving puts AI in a complex, unpredictable world where rare events can have severe consequences and decisions can’t wait. Our Head of New Technology and Collaboration, Jonas Ekmark, explains why Zenseact’s advantage lies not in any single algorithm, sensor, or dataset, but in the know-how, engineering discipline, and safety culture required to turn promising technology into a reliable product.
6 min read
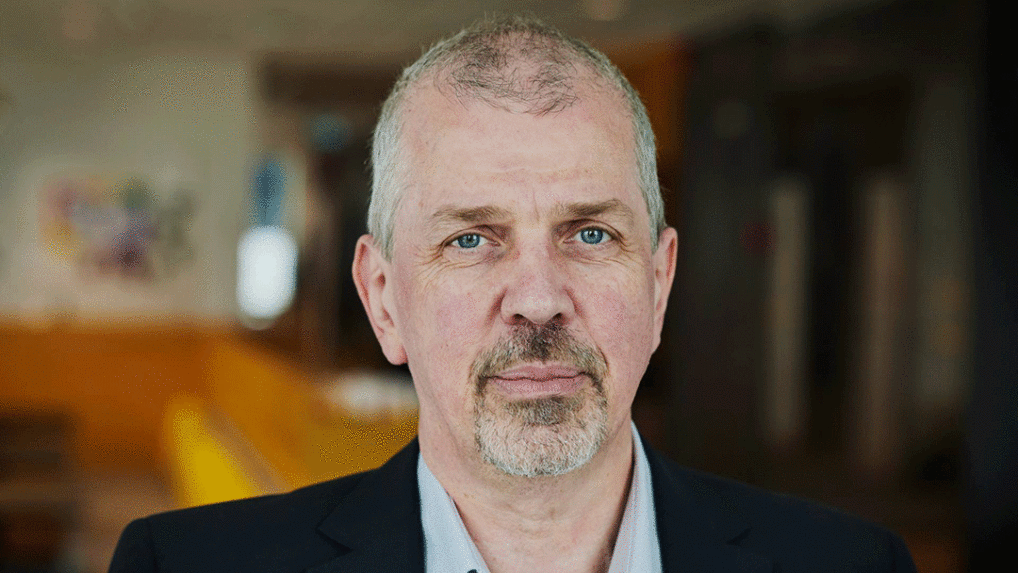
For Jonas Ekmark, the defining challenge of physical AI isn’t simply that it acts in the real world. It’s the kind of world it must act in.
A machine sorting clothes works within a relatively limited set of choices. A robot assembling parts on a factory line follows another tightly defined process. A vehicle in road traffic does not. Its environment is continuous; it must make real-time decisions, and the range of possible situations is nearly unlimited.
In this chaotic environment, the system must also avoid collisions, damage, and, above all, personal injuries. It simply can’t malfunction. But even that’s not enough. A robot assembling ball bearings really only needs to do its job correctly. It doesn’t have to perform it as gracefully, smoothly, and intuitively as an experienced mechanic. For a self-driving car to earn skeptical consumers’ trust, however, it can’t just follow traffic rules. It should also drive better than the average human, no matter the traffic scenario or conditions. In short, automotive AI needs to exceed human standards. Everywhere, all the time.
The long tail of the road
To make matters worse, traffic combines two difficult properties: some situations are extremely unlikely, yet their consequences can be severe. This “long tail” requires a car to cope with events that may occur too rarely to be found through ordinary testing. “The combination of low occurrence and high severity is the worst combination,” Ekmark says. That is also why the familiar idea of fixing every bug and then shipping the product doesn’t work for self-driving technology. The list of possible issues is simply too large, and manual testing will never uncover them all.
From impressive demo to dependable product
Zenseact’s experience of launching advanced driver-assistance systems provides a foundation for this work. The methods developed over years, collecting representative data, evaluating system responses, and balancing false negatives against false positives, remain relevant whether a solution is AI-based or rule-based. An emergency-braking system, for example, can fail by not braking when necessary – or by braking when it shouldn’t. Both errors matter.
The answer is not one perfect test, but a portfolio of methods: field-test datasets built around real-world user profiles, simulation at different levels, large databases for evaluation, and dedicated guardrails for particular situations. Even with all of these in place, developers limit the operational design domain (the conditions and areas in which a system is allowed to drive) to make the problem more manageable. “It’s quite easy to make a demo,” Ekmark says. “It’s more challenging to make it reliable and safe for the road.”
End-to-end AI still needs a safety net
Across the automotive industry, one central question is how to combine traditional rule-based systems, specialized components, end-to-end models, and foundation models. In a pure end-to-end approach, a model is trained on raw inputs and expected outputs to discover what matters. In theory, this could work with unlimited data and compute. In practice, both are limited, so the industry is exploring hybrid solutions.
Foundation models can hold more world knowledge than can fit in the car itself, then help train or distill that knowledge into the in-car system. But while end-to-end models are not inherently safe enough, independent guardrails remain necessary. Ekmark compares this with redundancy in commercial aircraft, where another system can step in if one fails, or with a journalist checking information against an unrelated source. Parallel methods are especially valuable when uncertainty remains. One day, models may become reliable enough to make some guardrails unnecessary, he says, but “we are not there yet.”
Fitting the pieces together
AI is also changing how the product is developed. At Zenseact, support is being introduced step by step across requirements, design, verification and validation. Ekmark believes the biggest changes are still ahead: AI will touch almost every development process and methodology. The transformation will be profound, but it will not happen all at once.
Physical AI needs algorithms, data, infrastructure, a software factory, and skilled people – not one breakthrough component. Asked which technology will reshape automotive AI most over the next five years – better models, sensors, compute, simulation, synthetic data, or robotics convergence – Ekmark resists choosing one. All are advancing. The more decisive factor may be the know-how required to combine them. Many competitors have the pieces; the “secret sauce” is the methodology for connecting them and using them optimally. The same applies to data pipelines, training and verification infrastructure, which take years to build and refine.
Beyond the passenger car
Much of that capability is transferable beyond passenger cars. Real-time control, reliable performance, handling previously unseen situations, and preventing harm are common requirements across physical AI. So are the data pipelines, training methods, and verification practices needed to work at scale. The underlying robotics pa[JE3] radigm – sense, plan, act – remains relevant even as the models and machines become more sophisticated.
Success means making safety effective and affordable
Looking toward 2030, Ekmark expects self-driving technology to achieve its first major breakthroughs in commercial transport and taxi services. Yes, there are robotaxis, but not yet on a large scale, and they are not yet profitable or widely accepted. Still largely a test or pilot operation. Waymo is the largest, with about 3,500 robotaxis in commercial operation. Uber has about 10 million manually driven vehicles.
He also sees potential in general-purpose humanoid robots once they become clearly profitable, while purpose-built machines from cleaning robots to lawn mowers are already spreading quietly because they perform narrow tasks efficiently.
Yet the standard for success isn’t novelty. It’s impact. Road-traffic losses remain unacceptably high, and the work isn’t done until safety technology is both effective and affordable enough to make a meaningful difference worldwide. In Ekmark’s view, trust depends on transparent evidence, rigorous verification, and a safety culture that permeates every software update. And, more broadly, everything Zenseact does. It shapes the development process, the tools engineers use, and how decisions are made, helping ensure safety is built into every release. That is why physical AI is ultimately as much an engineering and organizational challenge as a technological one.